Prototyping Manager
Advanced Telerobotics Research (ATR) Lab, Kent State University
- Integrate actuators, sensors and embedded hardware into research robots.
Wiring sensors, motors and microcontrollers into working control boards, and writing the firmware that runs them.
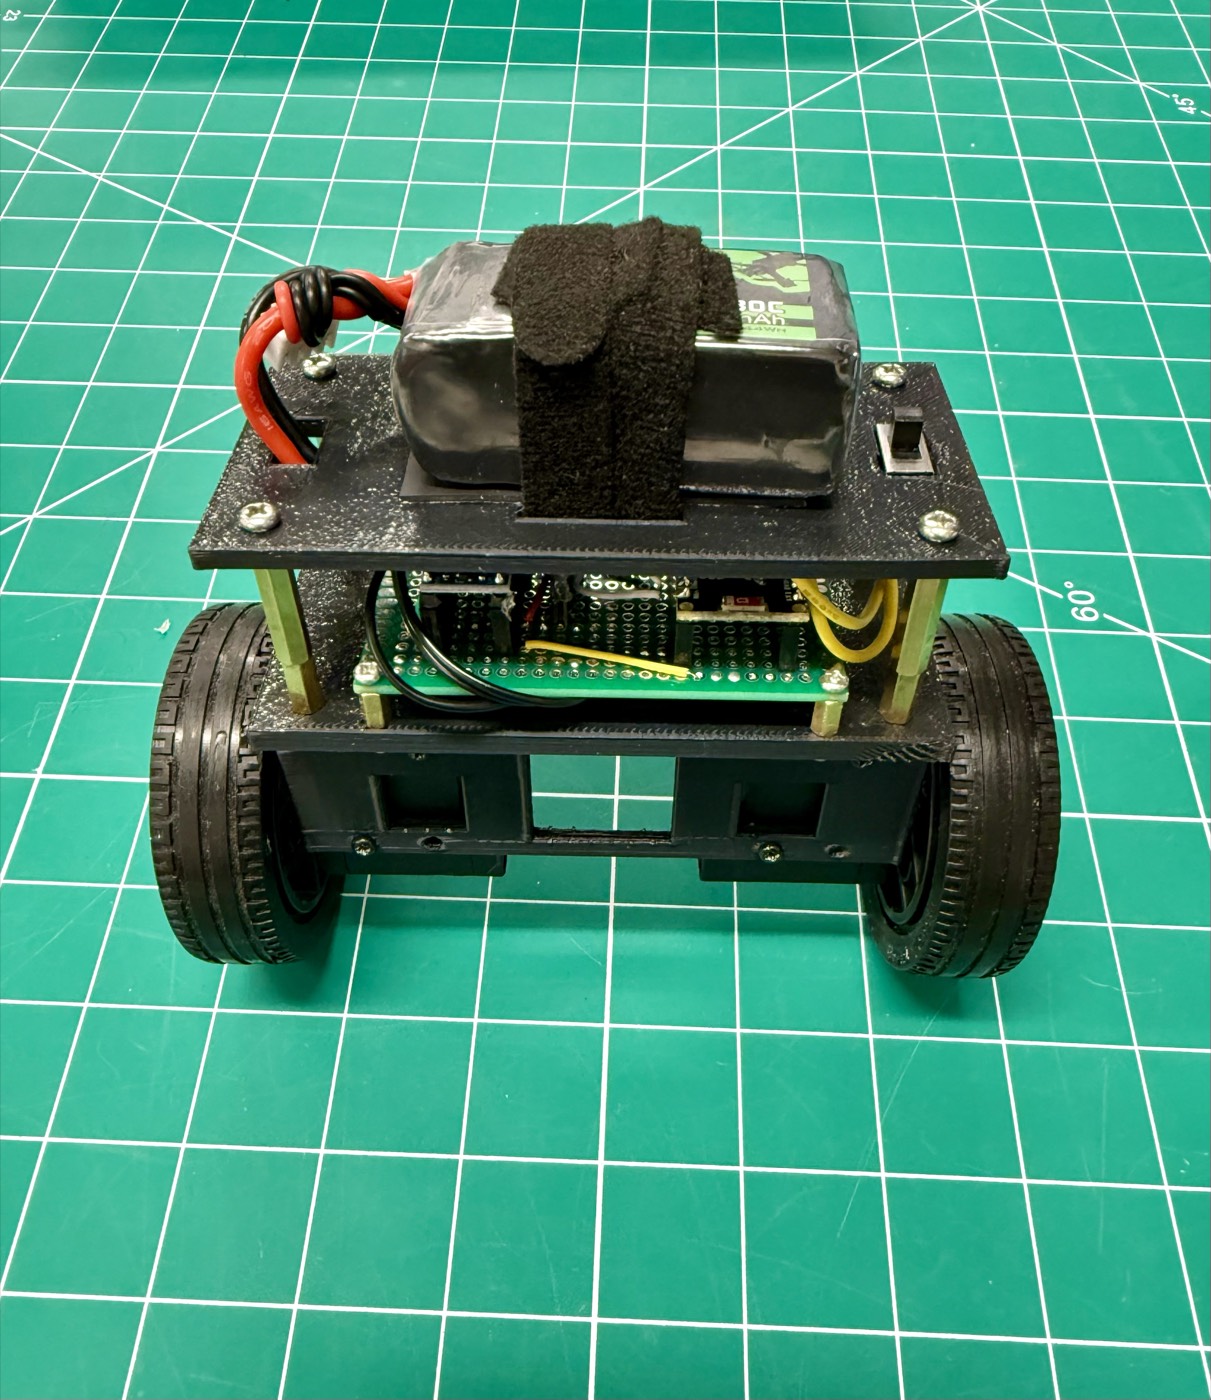
A small two-wheeled robot that balances on its own, like a mini Segway, and can be driven and tuned over Wi-Fi from a PC app.
View project →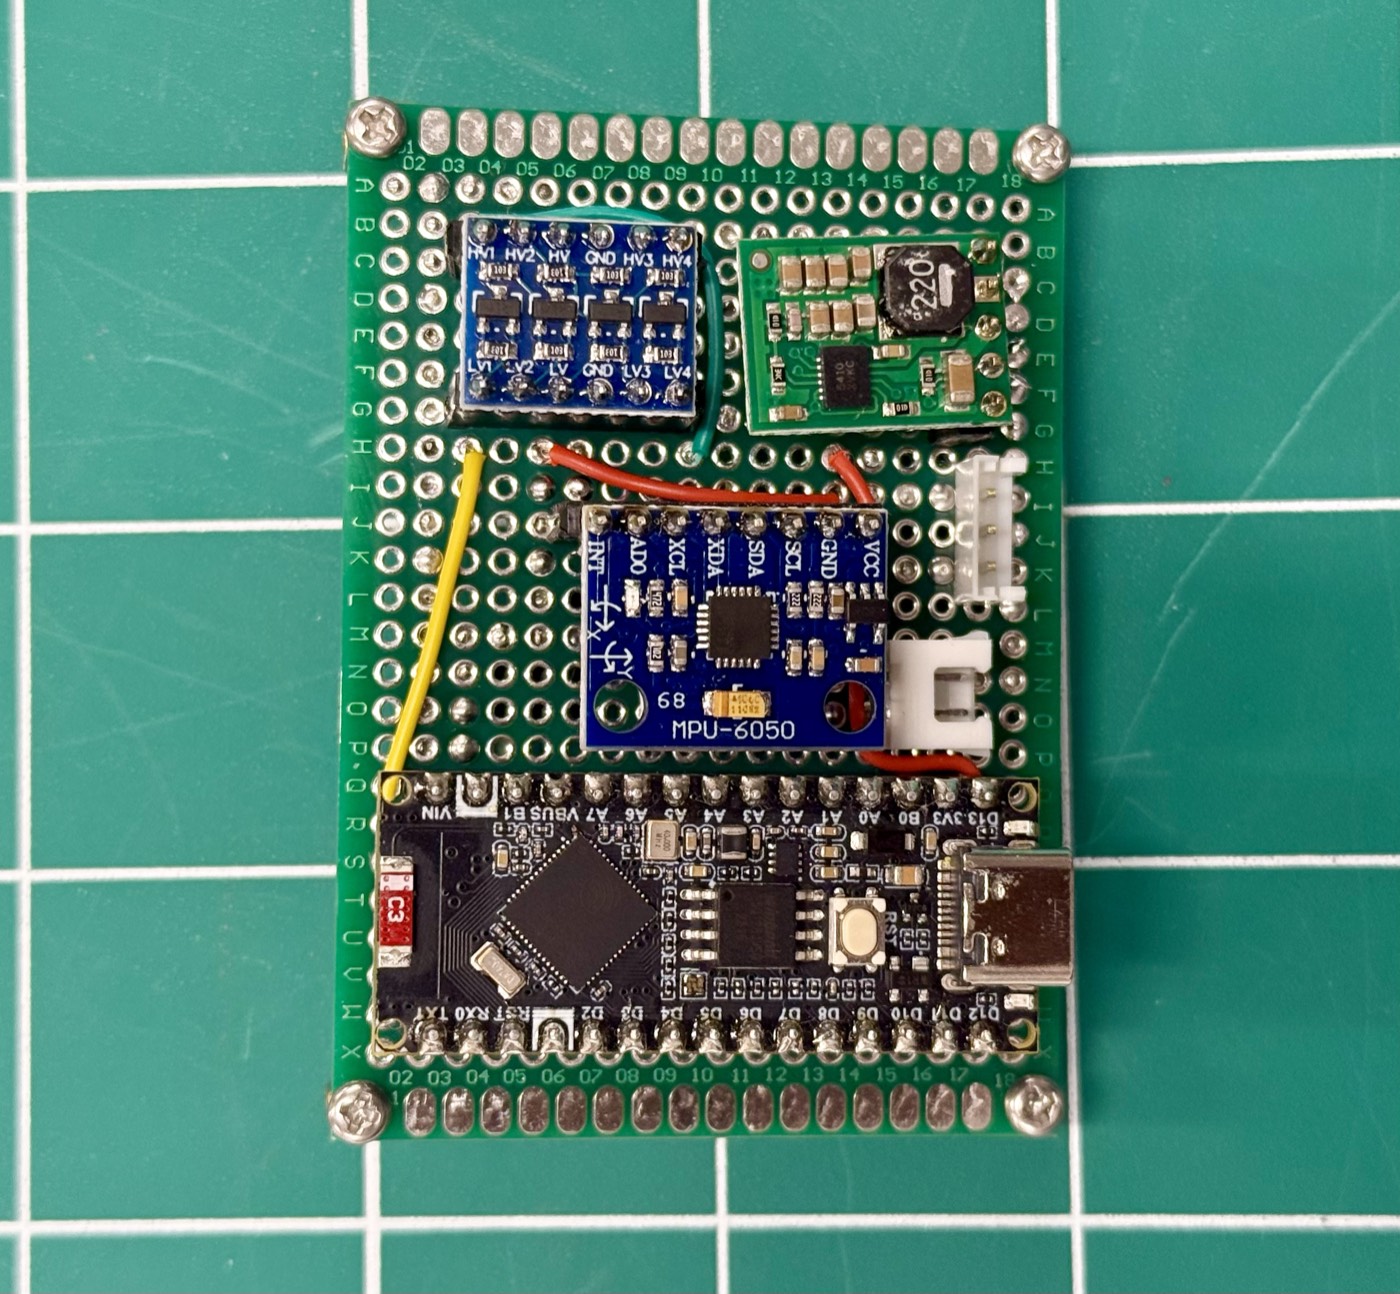
How to talk to devices that share one data wire, like DYNAMIXEL smart servos, using the ESP32's normal UART, one jumper wire and a few lines of code.
View project →An expressive robotic head combining mechanical motion systems and embedded electronics.
View project →